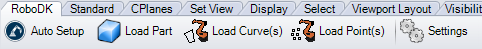
●Settings – Open the default Settings window. This is the same settings window shown for each grasshopper component. This button corresponds to the RoboDK_SetDefaults command.
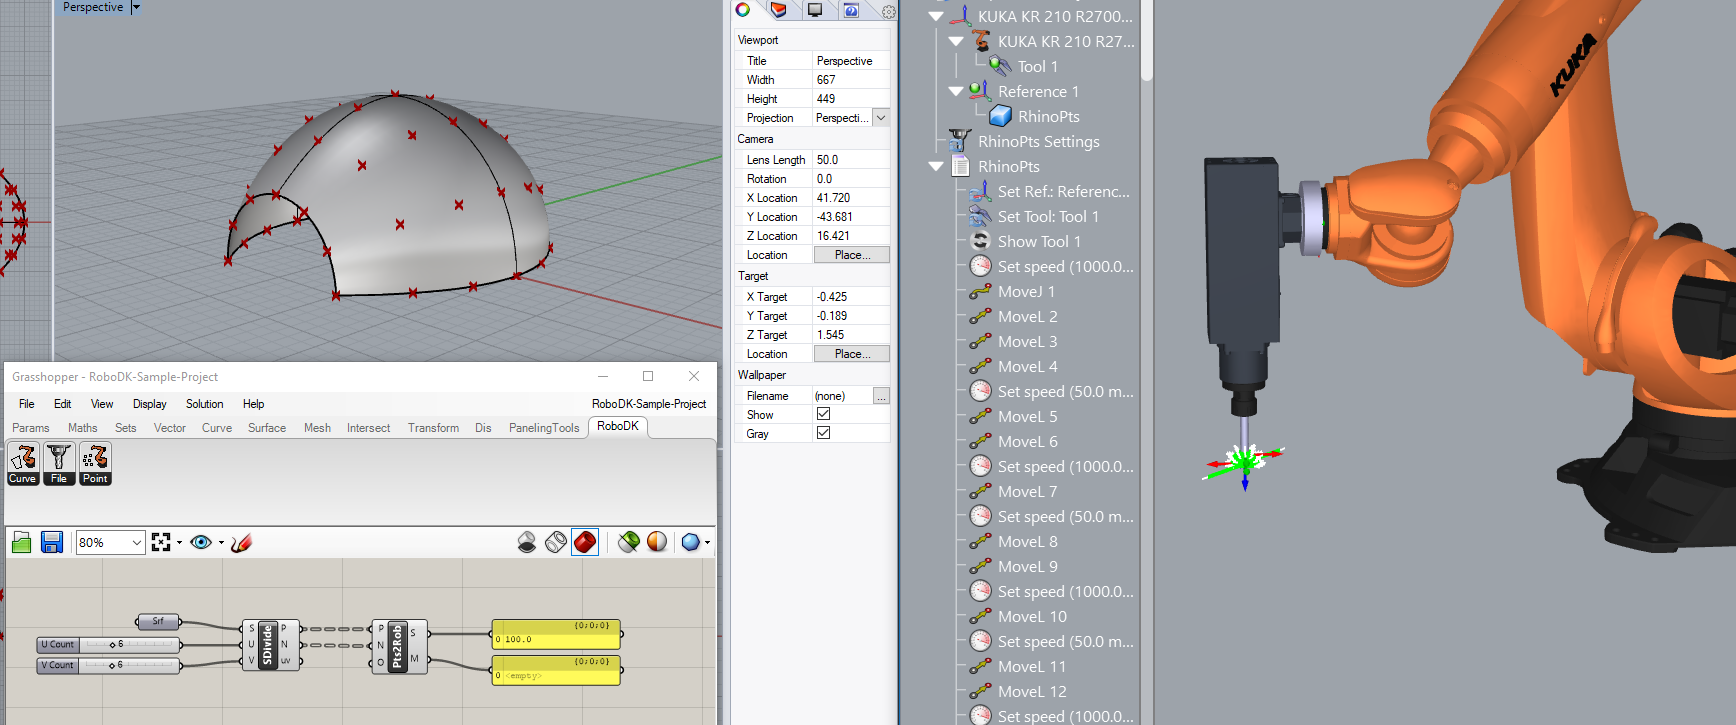
●Load Point(s) – Load all the points selected in RoboDK as a new object. All selected surfaces will be used to calculate point normals. These normals are important as they will define the robot’s approach axis. This button corresponds to the RoboDK_Points2Robot command.
●Load Curve(s) – Load all the curves selected in RoboDK as a new item. All selected surfaces will be used to calculate curve normals. These normals are important as they will define the robot’s approach axis. This button corresponds to the RoboDK_Curve2Robot command.
● Auto Setup – This button allows you to select any geometry (curves or points) and they will be loaded in RoboDK together with the 3D model. This button corresponds to the RoboDK_AutoSetup command.
●Auto Setup - 该按钮允许您选择任何几何体(曲线或点),它们将与 3D 模型一起加载到 RoboDK 中。此按钮对应RoboDK指令:RoboDK_AutoSetup。
●Load Part -将3D模型从Rhino加载到RoboDK。曲线或点等特征不会被加载。此按钮对应RoboDK指令:RoboDK_Part2Robot。
Auto Setup 与Load Curve(s) or Load Point(s) 的核心区别在于: Auto Setup 会同时导入3D模型并创建全新的曲线/点跟随项目(重置所有参数)。 Load Curve(s) or Load Point(s) 仅更新RoboDK中现有几何特征,保留已定义的机器人设置(如工具帧、参考系等),执行效率更高。"